Interpret measurements and demonstrations
Use this page to interpret an experiment. Videos show individual recordings, not an accuracy specification for every arm or a result automatically reproduced by installing a supplied profile.
Distinguish the measurements
| Measurement | Question it answers |
|---|---|
| Repeatability | How close are positions when the same operation is repeated? |
| Absolute accuracy | How close is the physical position to the commanded physical target? |
| Tracking error | How far is measured position from the current planned reference? |
| Destination error | How far is the motor from the command’s final destination, including during travel? |
| Mechanical deflection/backlash | How do load and mechanics change link and endpoint positions? |
Matching encoder counts does not directly measure tool position in space. One successful return does not characterize the complete workspace.
Repeatability and accuracy
Repeated returns measured with an indicator:
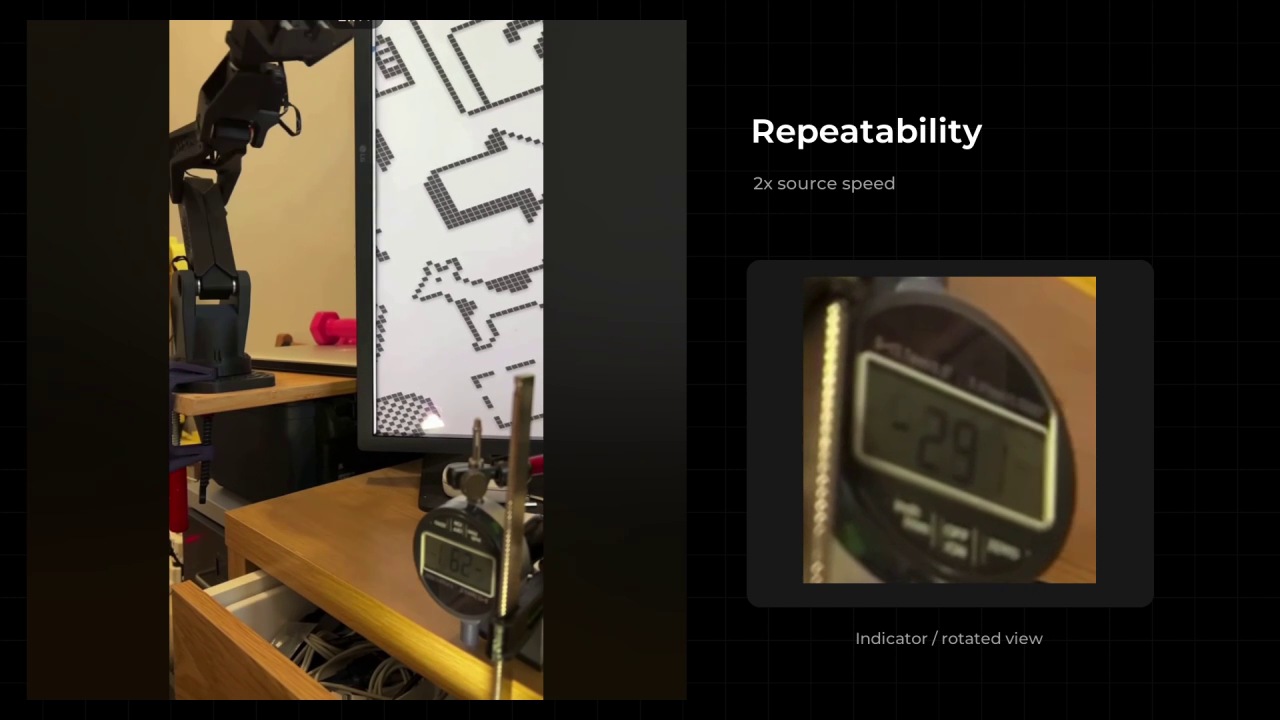
This recording illustrates repeatability in one experiment. Record payload, mounting, approach direction, repeat count and measurement method when comparing results.
A conceptual explanation of spread and offset from the target:
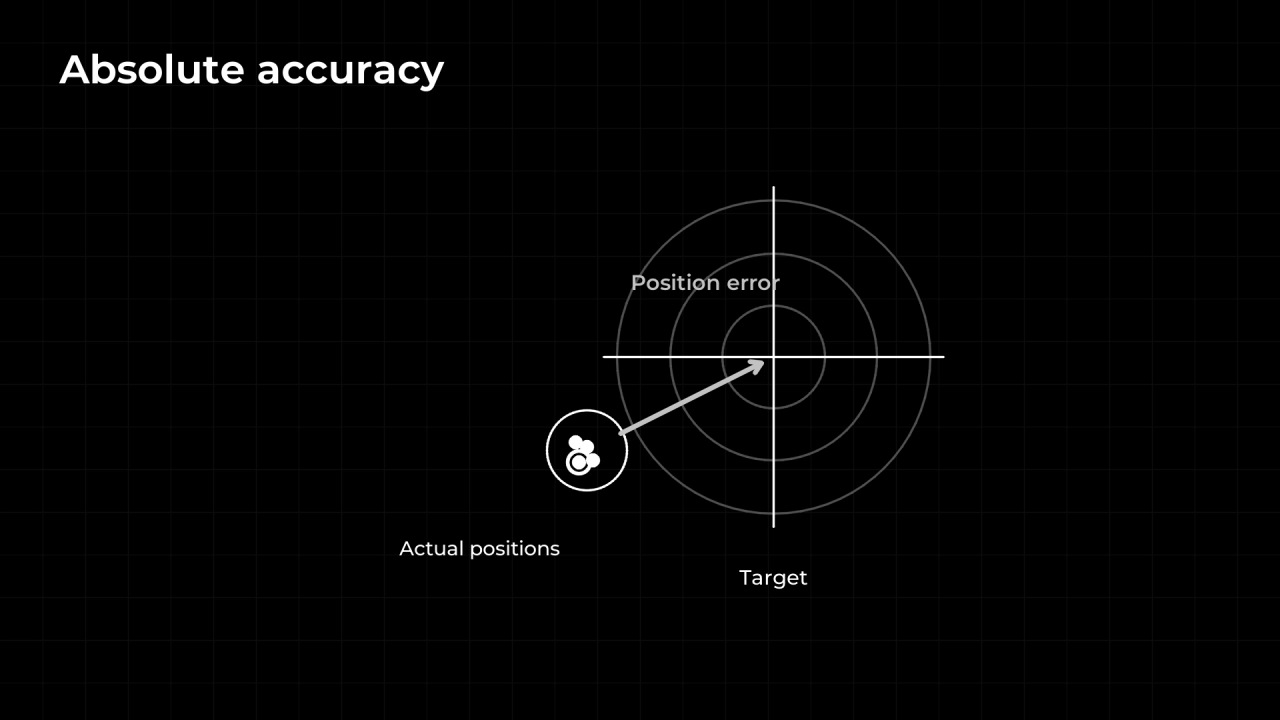
This animation explains concepts; it is not a measured hardware dataset.
Oscillation and before/after recordings
An example of oscillation during stock-firmware PID tuning:
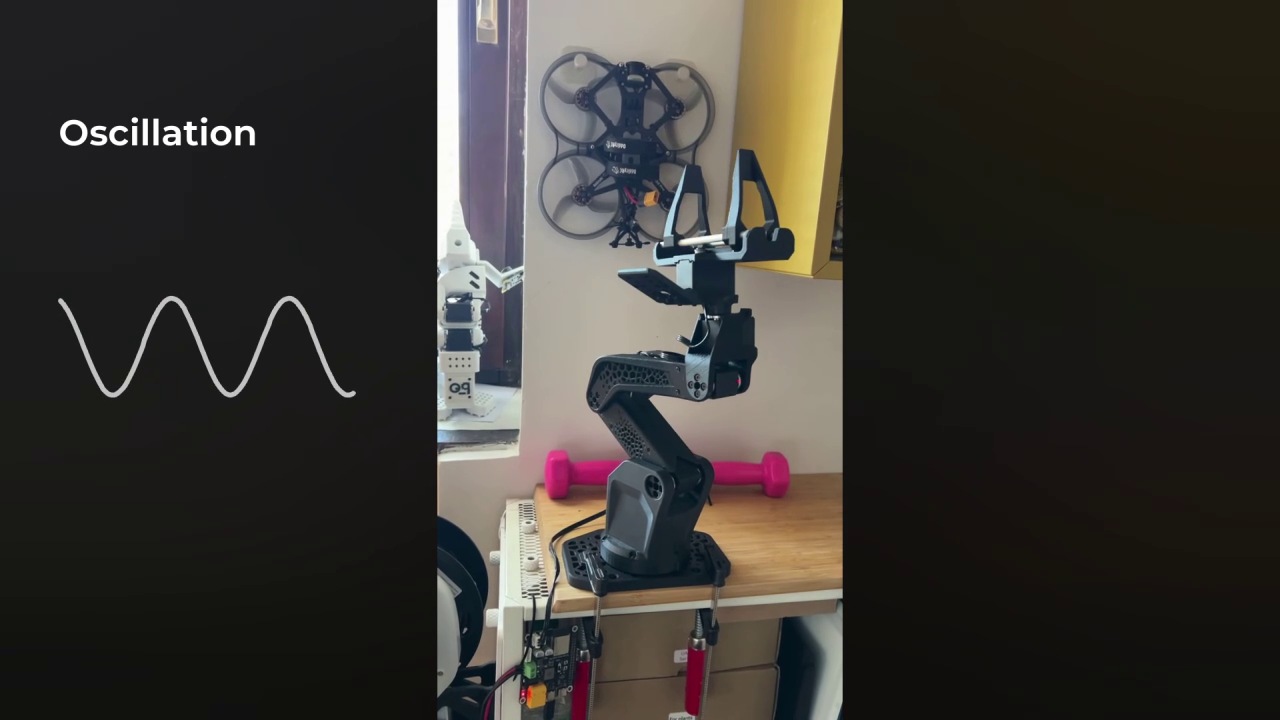
In some recorded tests, lower position error was accompanied by oscillation. This motivates checking overshoot, longer holds, load and saturation as well as static error; it does not establish universal factory-firmware behavior.
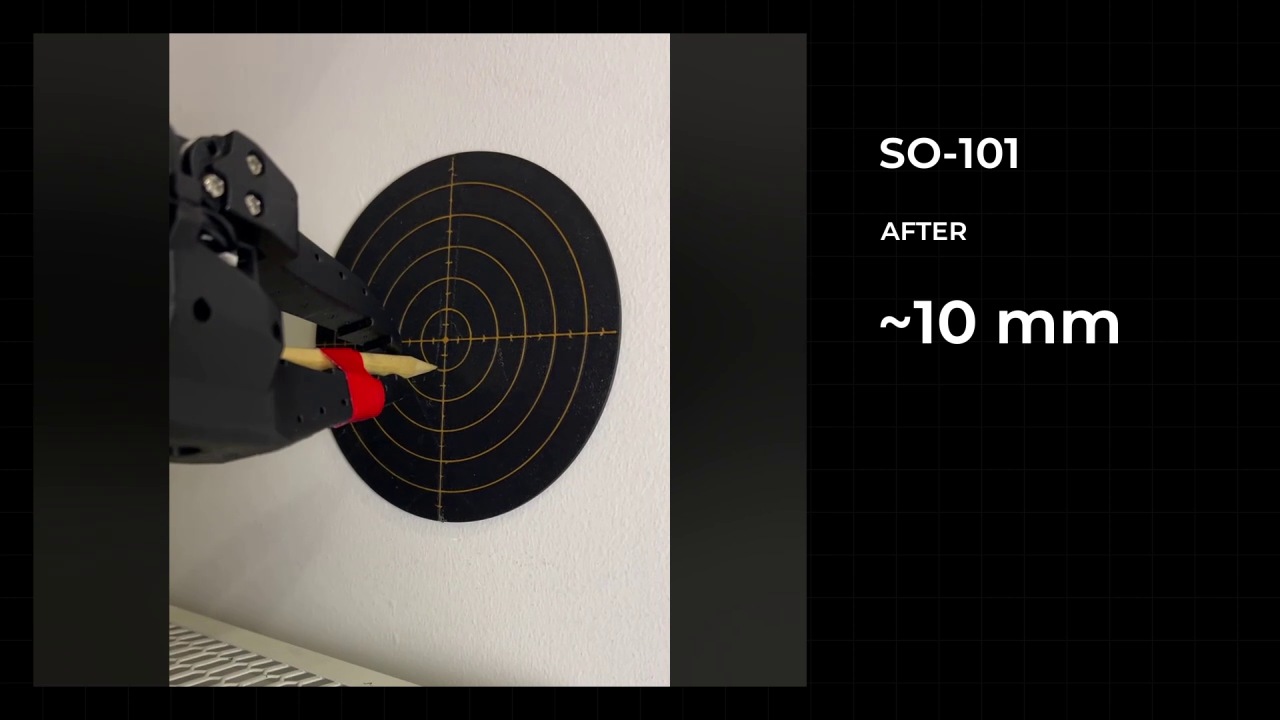
Combined comparison recording:
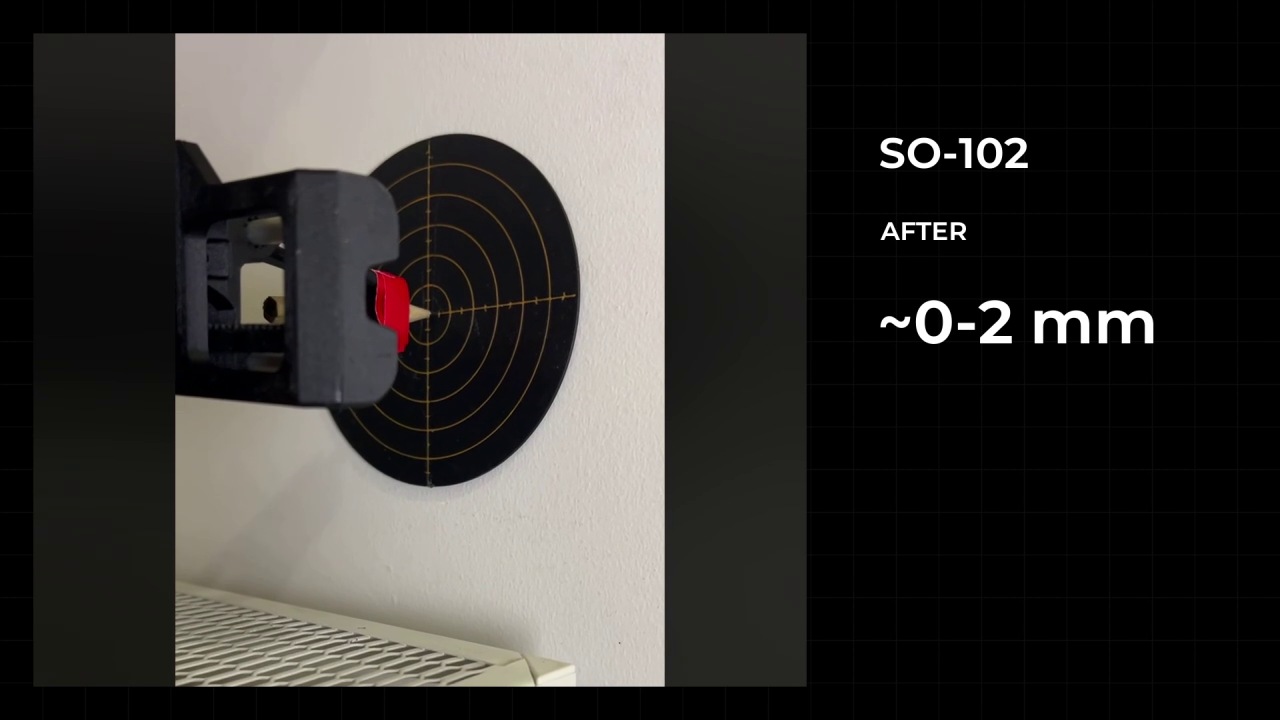
SO-101: original behavior followed by the changed setup:
SO-102: original behavior followed by the changed setup:
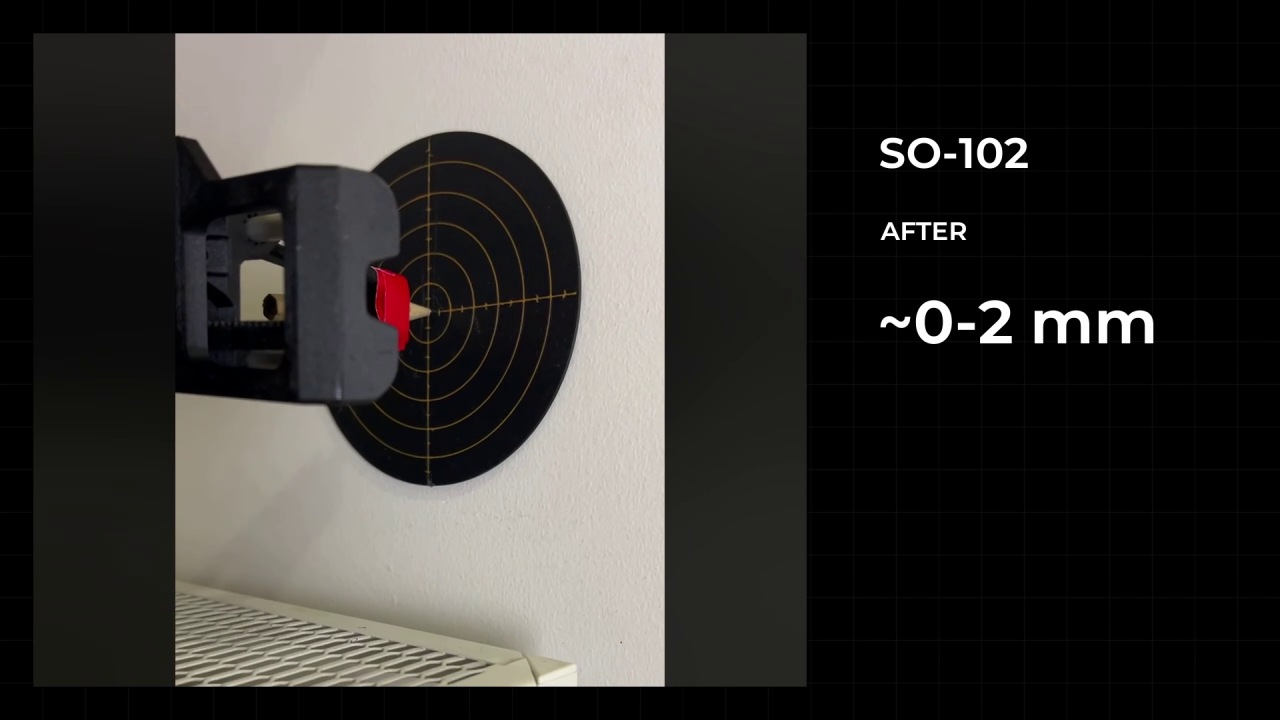
Approximate displayed values describe those demonstrations. Current profiles do not necessarily reproduce historical recordings: the current SO-102 profile differs from an earlier replay in M1 D, M6 P and ramp time. Reproducible comparison requires the profile, calibration, model, payload and recording versions.
Coordinated movement and mechanics
A recording of coordinated movement:
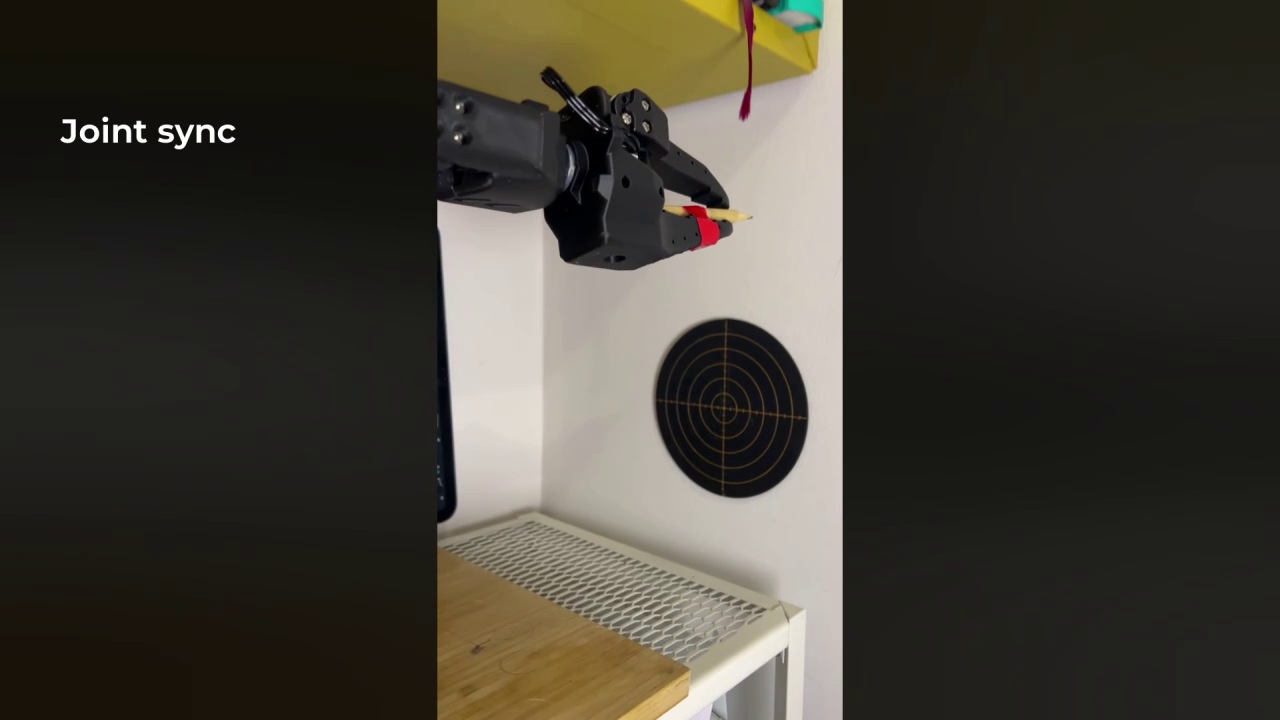
Each servo plans its own profile. Group targets and distance-scaled speeds assist coordination but do not guarantee a common arrival time.
Gearbox backlash and frame flex:
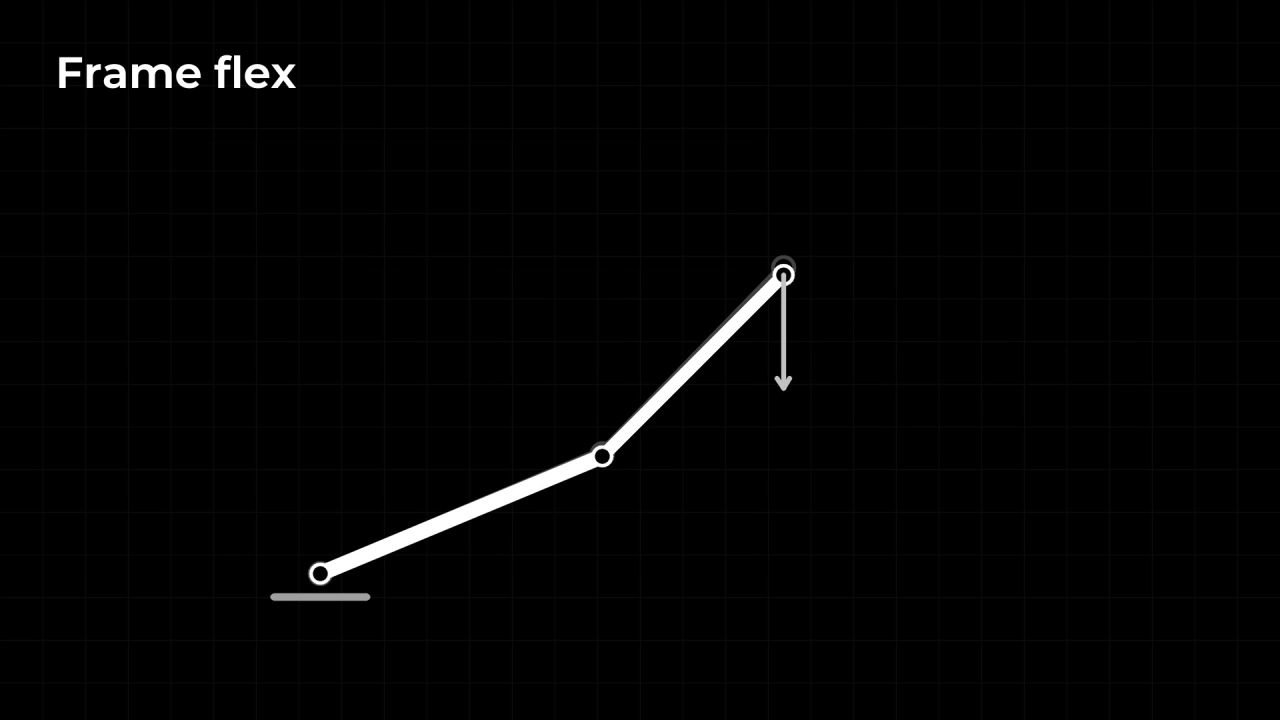
Control tuning does not eliminate mechanical backlash or structural compliance. Record experimental conditions and distinguish motor error from endpoint position. Use tuning validation to accept settings and the viewer to inspect counts and references.
Documentation home · Source revision: a995f77. Extension 9.0.